Astiron Optical Track
Precision electro-optical and infrared target tracking for counter-drone defense.
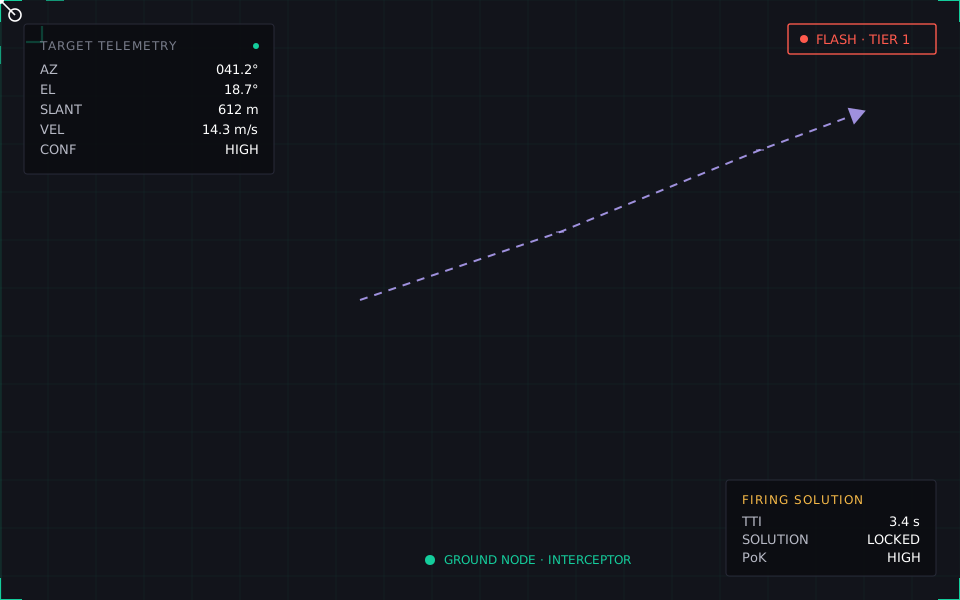
Continuous day/night visual acquisition and tracking engineered for mobile air defence units and forward asset perimeter security.
Astiron Optical Track serves as the visual confirmation and precision tracking layer in counter-UAS architectures. Upon receiving initial cueing from radar or acoustic sensors, it slews onto the target sector, acquires the aerial contact across visible and thermal spectra, and maintains a continuous line of sight for positive identification and engagement decisions.
Engineered for sovereign isolation and contested warfare.
Every component is architected from first principles to operate without reliance on commercial cloud providers or external connectivity.
Multi-Spectral Continuous Lock
Fuses visible light contrast and thermal infrared signatures to maintain target tracking through dynamic illumination and dusk transitions.
Autonomous Slew & Cueing
Accepts rough bearing and range hand-offs from radar and acoustic sensors to rapidly point and acquire moving micro-UAS targets.
Low-Latency Fire-Control Telemetry
Provides high-frequency line-of-sight tracking data necessary for operator classification and defensive response systems.
Signal-to-Decision Sequence
Sensor Cue Hand-Off
Receives initial azimuth and elevation cues from radar or acoustic perimeter detection systems.
Visual Lock & Classification
Slews gimbal to target coordinates, locks bounding box, and surfaces high-resolution optical feed to operator.
Continuous Track Telemetry
Calculates kinematic trajectory vectors and maintains steady target line of sight until engagement completion.
Detecting a drone is easy. Tracking it long enough to stop it isn't.
Technical evaluation, telemetry benchmarks, and architecture specifications from the Astiron Defence Engineering Lab.